Origami Desk
Origami on your desk, today.
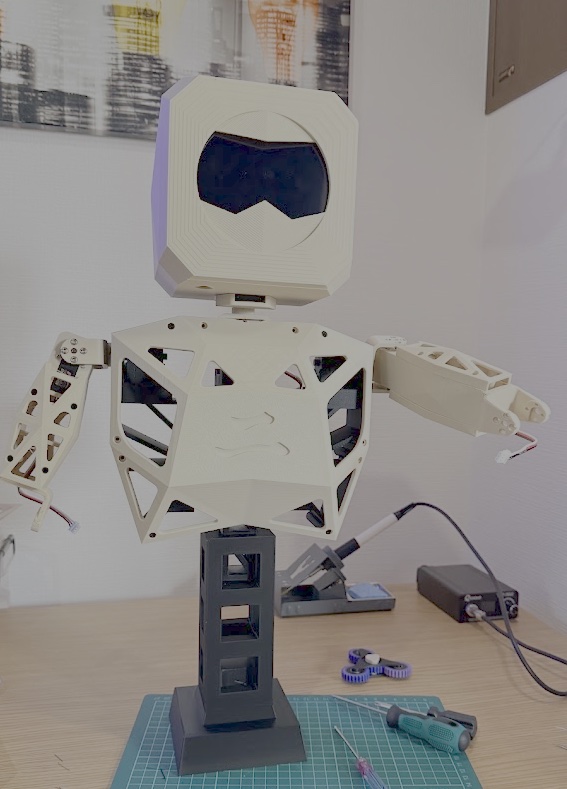
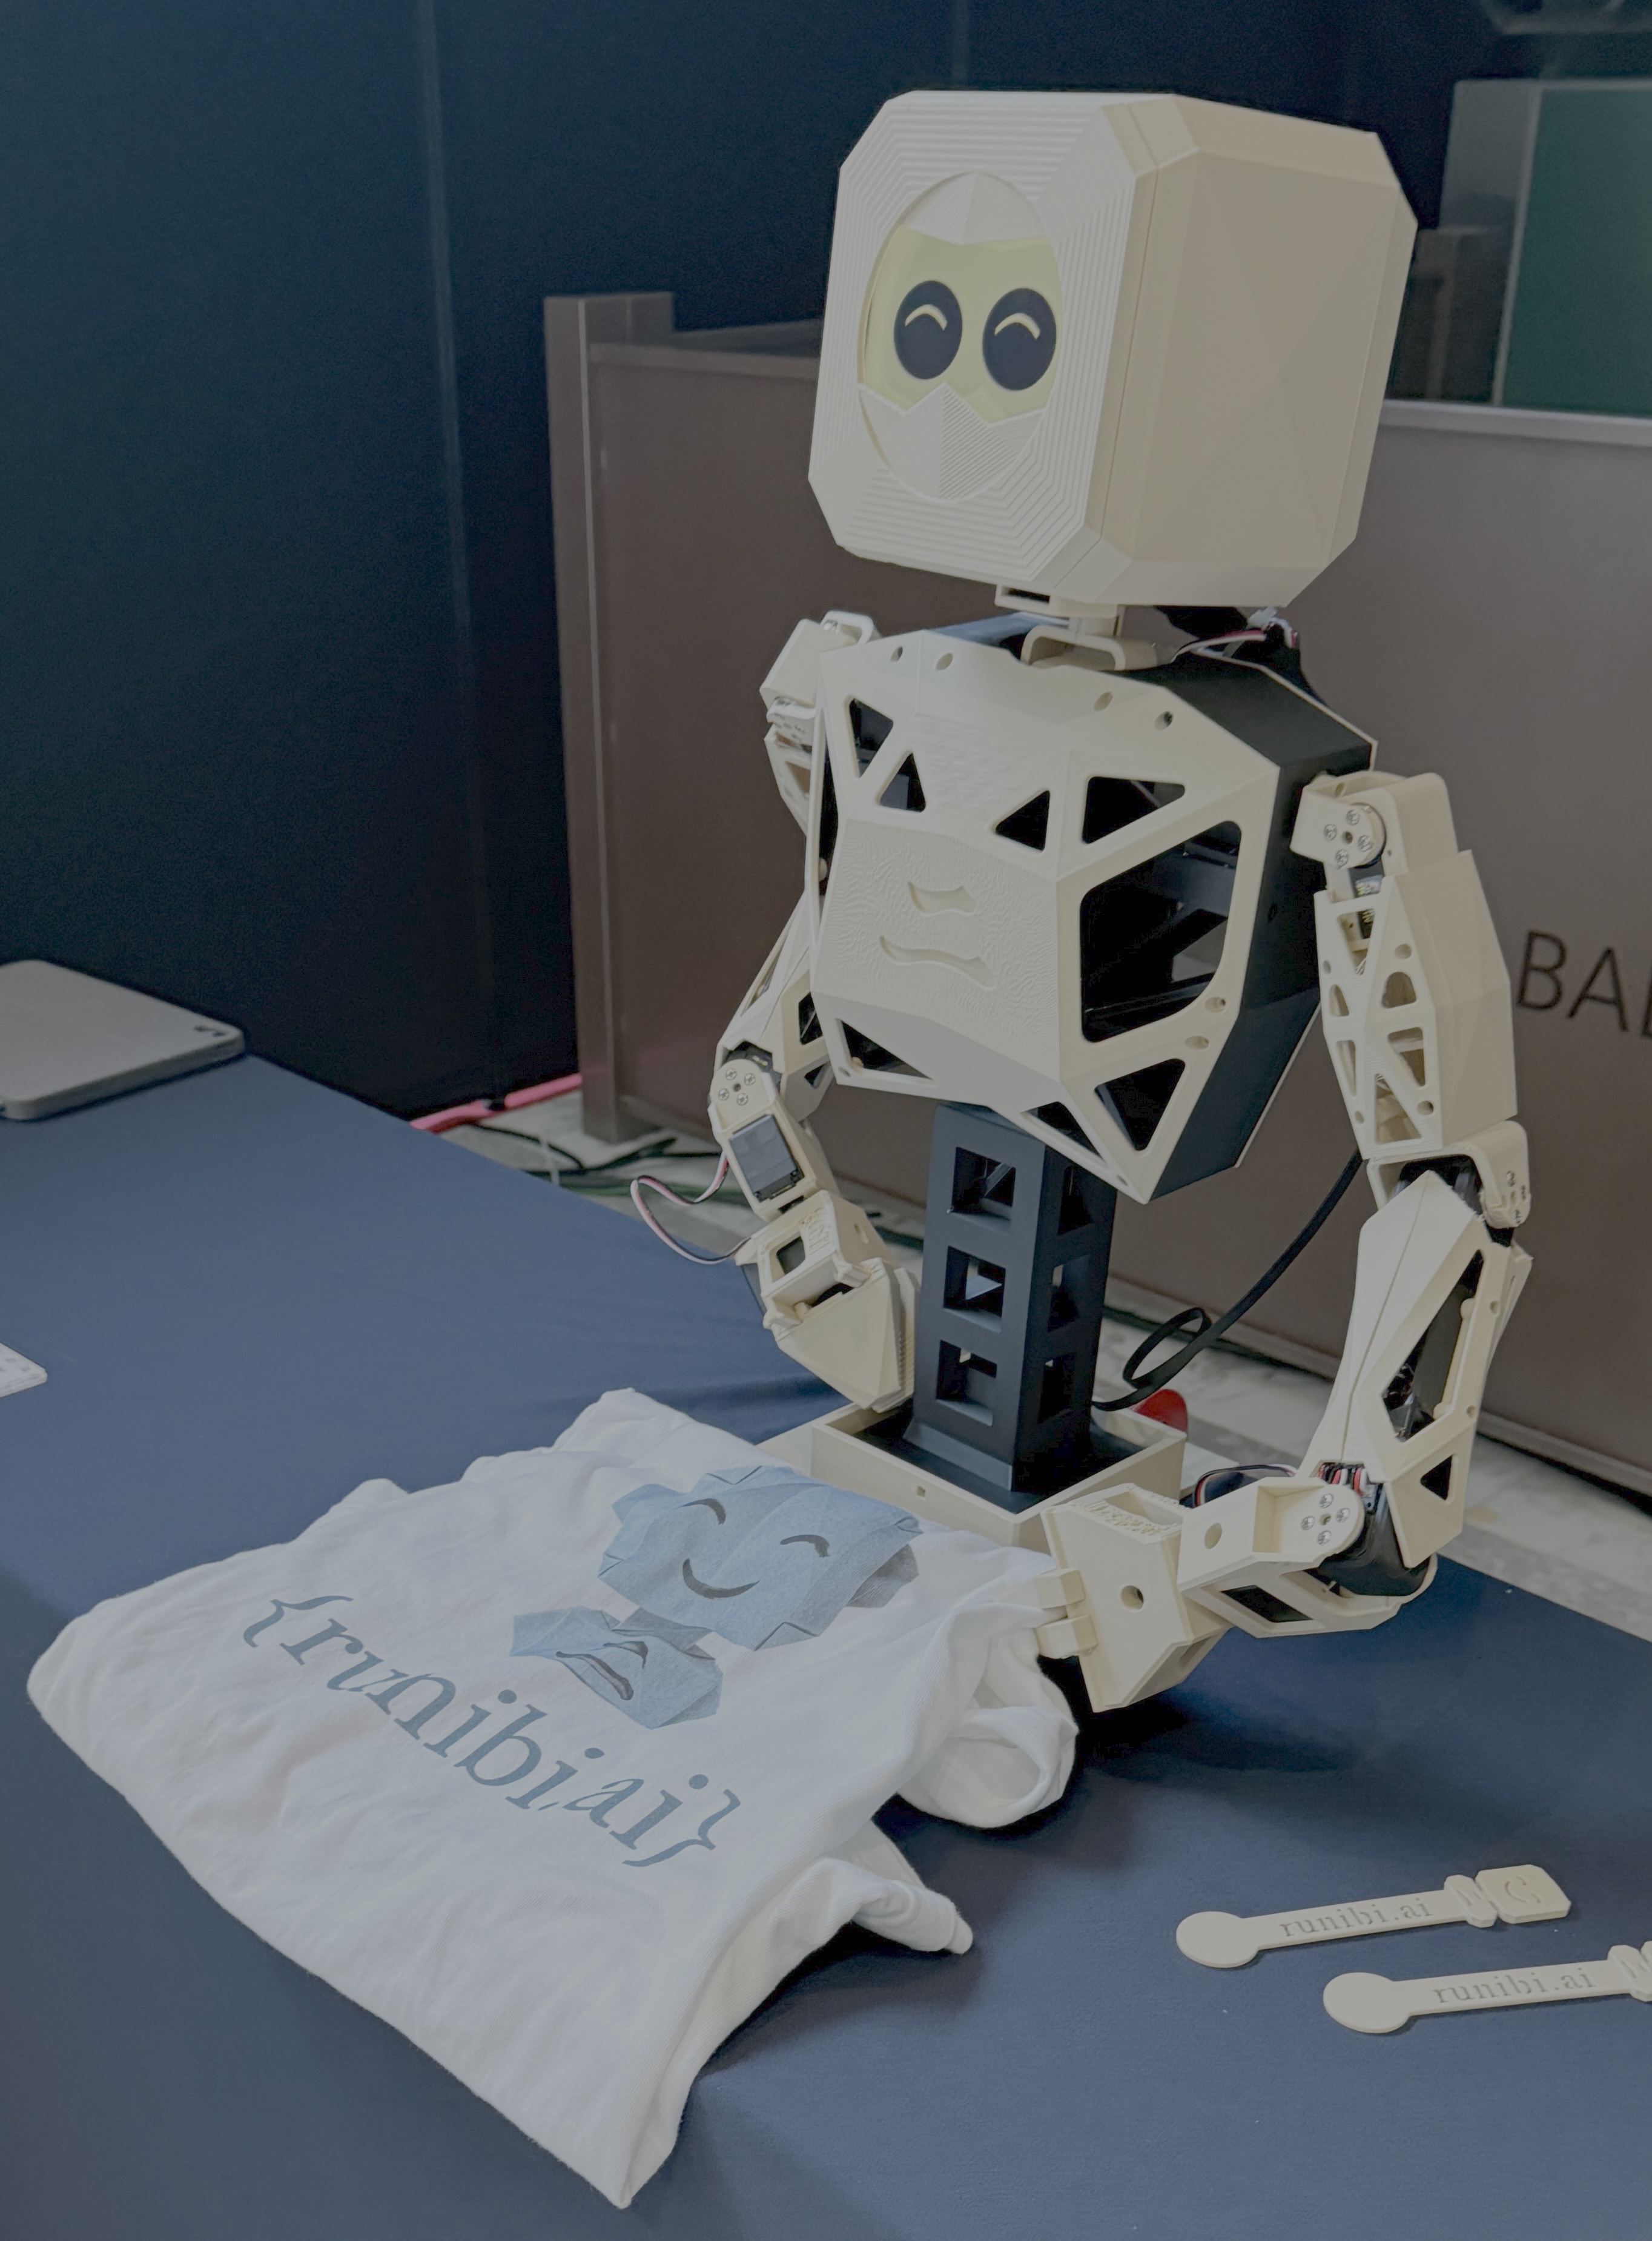
Head, two arms and a face. Start building now; the walking robots run on the same stack.
- Browser twin included
- Discord community
- Setup call for the first 100
Origami is a real humanoid you can own, teach and take apart. Join the developers shaping what it becomes, from the very first version.

Origami on your desk, today.
Head, two arms and a face. Start building now; the walking robots run on the same stack.

The full humanoid, ready to go.
Delivered assembled, with warranty and support, and two years on the training platform. Nothing to build.

Build it with us.
The same walking humanoid, built by you, with our team and the community. This is how you join the early access developers program.
Early access is limited. We review every application personally.
Every developer starts somewhere. Origami grows with you, from a quick demo to skills you trained yourself.
Run a demo and see Origami move in minutes. No code.
Guide its arms by hand. It records the motion and plays it back.
Turn your demonstrations into skills it repeats on its own.
Train advanced AI models in simulation, then bring them to the real robot.
| Category | Desk | Premium | DIY |
|---|---|---|---|
| Overview | 14 DoF · 57 cm · 2,795 g · upper body on desk | 27 DoF · ~110 cm target · ≈ 22–25 kg est. | 27 DoF · ~110 cm target · ≈ 18–22 kg est. |
| Kinematics | Neck 2 · arms 6 each (incl. gripper) | Neck 3 · arms 7 each · legs 5 each | Neck 3 · arms 7 each · legs 5 each |
| Interaction | 5″ touchscreen face | 5″ touch face · 4-mic far-field array · speakers · cloud AI voice | 5″ touch face · 4-mic far-field array · speakers · cloud AI voice |
| Manipulation | 2 × 6 DoF arms · 1-DoF grippers | 2 × 7 DoF arms · 1-DoF grippers · 600 g payload target | 2 × 7 DoF arms · 1-DoF grippers · 600 g payload target |
| Locomotion | Stationary | Bipedal walking | Bipedal walking; quality depends on build and calibration |
| Sensing | Joint position and load | 3 wide cameras (head, chest, hand) · IMU · position, current and temperature per actuator | 3 wide cameras (head, chest, hand) · IMU · position, current and temperature per actuator |
| Compute | Single-board computer | Higher-performance AI compute module | AI compute module + real-time motor controller |
| Actuation | Smart servo motors | Humanoid-class quasi-direct-drive actuators | Quasi-direct-drive actuators (printable) |
| Power | 12 V tethered | 48 V battery · emergency stop · charger | Battery · emergency stop · charger |
| Structure | Printable plastic | Aluminum frame + soft printed shells | Printed parts |
| Connectivity | Wi-Fi, Bluetooth | Wi-Fi, Bluetooth, Ethernet | Wi-Fi, Bluetooth, Ethernet |
| Software | Record and replay · browser twin | Record and replay · teleoperation · learned policies · SDK | Record and replay · teleoperation · learned policies · SDK |
Walking-robot specifications are design targets and may change.
Open-ended conversation uses a cloud AI model and needs internet.
Try the simulation right now — or reserve your Origami humanoid for early access.
Reach out to us if you want to know more details.